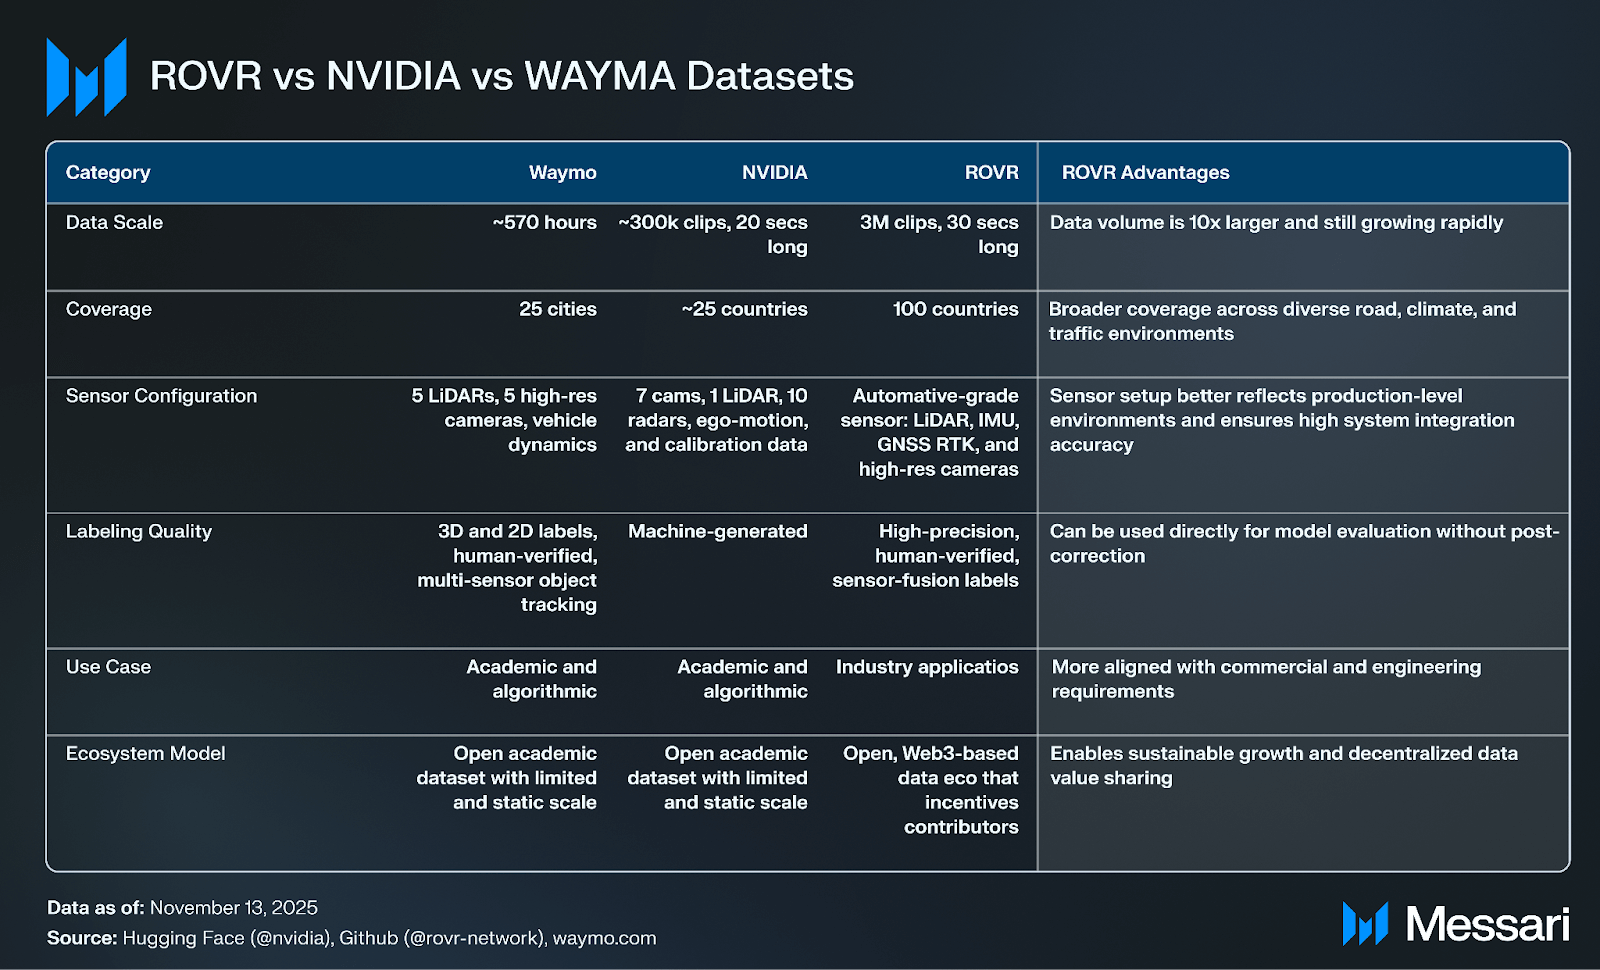
ROVR’s dataset exceeds 30 million kilometers of driving data across 100+ countries and over 1 million hours, with its size approaching 1 PB, far surpassing NVIDIA’s 1,727 hours and Waymo’s 570 hours.
ROVR’s contributor-driven model enables continuous, near-real-time updates, capturing new environments faster than centralized fleets. NVIDIA and Waymo release updates on slower cycles, limiting responsiveness to emerging scenarios.
Unlike NVIDIA’s heavily restricted licensing and Waymo’s research-only access, ROVR combines open licensing (CC BY-NC-SA) with token incentives that reduce data-acquisition cost and drive continuous dataset expansion.
ROVR’s use of mixed consumer/semi-pro hardware accelerates data collection and supports long-tail environments. NVIDIA and Waymo use tightly controlled multi-sensor rigs producing consistent datasets, but far less geographic diversity.
Primer
ROVR Network (ROVR) is a decentralized physical infrastructure network (DePIN) that focuses on building a comprehensive geospatial data platform using specialized hardware and software solutions. Its mission is to collect and produce large-scale, highly accurate 3D geospatial and 4D spatiotemporal data from real-world environments, addressing the critical bottleneck in quality 3D data availability. This data is vital for training and deploying advanced systems, such as autonomous vehicles, robotics, and spatial artificial intelligence solutions. By democratizing access to critical resources traditionally monopolized by large corporations, ROVR empowers individual contributors to participate directly in the economic benefits of the AI-driven economy.
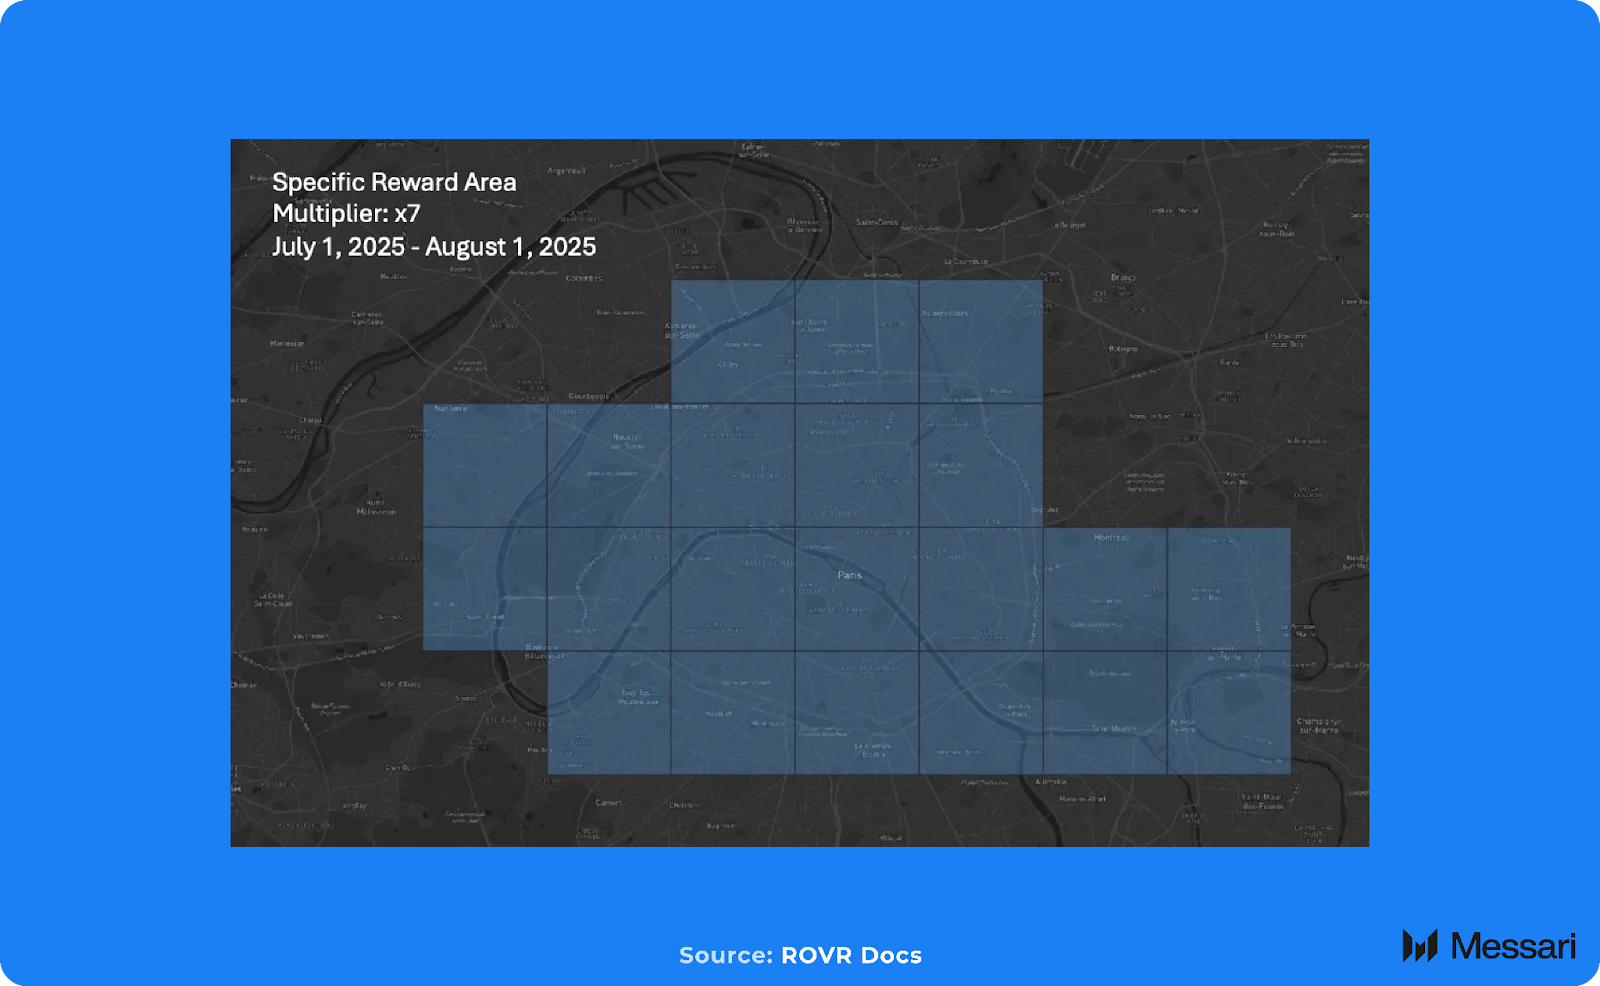
Data collection within the ROVR ecosystem relies on two specialized devices: TarantulaX (TX) and LightCone (LC). TarantulaX is a compact hardware device that mounts on the vehicle roof and links to a driver’s smartphone over Bluetooth. By feeding centimeter-level corrections from GEODNET, it turns everyday mobile video into accurate geospatial data. Meanwhile, LightCone is a roof-mounted sensor that pairs an automotive LiDAR, ADAS-grade camera, tri-band RTK satellite antenna, and high-precision IMU to capture centimeter-accurate 3D data. Users who contribute quality data are rewarded with ROVR tokens, incentivized based on factors including the amount of data collected (measured in mapping mileage), data quality, and frequency of road revisits.
The data gathered is subsequently transformed into high-definition maps that deliver centimeter-level precision and detailed environmental context, critical for applications such as autonomous vehicle navigation. ROVR's 3D data generation tools support the training of advanced AI models, enabling precise scene editing and the creation of synthetic data based on actual real-world conditions.
ROVR’s Open Dataset provides more than 30 million kilometers of driving data, collected from over 100 countries and encompassing a wide array of environments and road types. The initial public batch includes 3 million thirty-second clips, but the overall community-contributed dataset is rapidly expanding through the ongoing participation of individual contributors and organizations. NVIDIA’s PhysicalAI-Autonomous-Vehicles dataset, by contrast, comprises 1,727 hours of driving, organized into 310,895 twenty-second clips, spanning 25 countries and over 2,500 cities, with roughly half of the data originating from the U.S. and half from the EU. Waymo’s Open Dataset is smaller in geographic breadth (Phoenix, Kirkland, Mountain View, San Francisco). Still, it delivers over 570 hours of unique data, covering approximately 1,750 kilometers of roadways and featuring more than 20 million frames from its Motion Dataset alone.
ROVR maximizes global reach and organic growth via decentralization, NVIDIA balances coverage with controlled sensor deployments, and Waymo delivers deep, dense data from a highly instrumented, proprietary fleet. The result is a spectrum where ROVR favors breadth and community expansion, NVIDIA offers a hybrid of scale and curation, and Waymo focuses on depth and consistency within selected regions.
Sensor Modalities & Data Rig Quality
ROVR’s data is sourced from a mix of consumer and semi-professional-grade hardware. Contributors employ equipment bundles that may include 3D LiDAR, one front-view ADAS cameras, RTK GPS modules for precise localization, and IMUs for vehicle dynamics, with configurations varying by region and participant. This approach enables rapid scaling and adaptation to new markets but introduces variability in sensor fidelity, calibration accuracy, and environmental robustness.
NVIDIA’s dataset is built on its DRIVE Hyperion 8/8.1 platform, featuring an integrated, multi-modal sensor suite: seven RGB cameras (various fields of view and mounting positions), a top-mounted 360° LiDAR, and up to ten radar sensors (short, medium, and long-range models), all calibrated and synchronized for high-resolution data capture. Waymo’s proprietary sensor stack is even more advanced, combining five high-resolution LiDARs (one mid-range, four short-range) and eight 360-degree cameras, all synchronized and calibrated to produce unified multimodal representations of the environment.
ROVR’s diversity supports long-tail data collection and global adaptability, while NVIDIA and Waymo’s controlled sensor suites ensure consistency, high dynamic range, and repeatable results across all data segments.
Geographic & Environmental Coverage
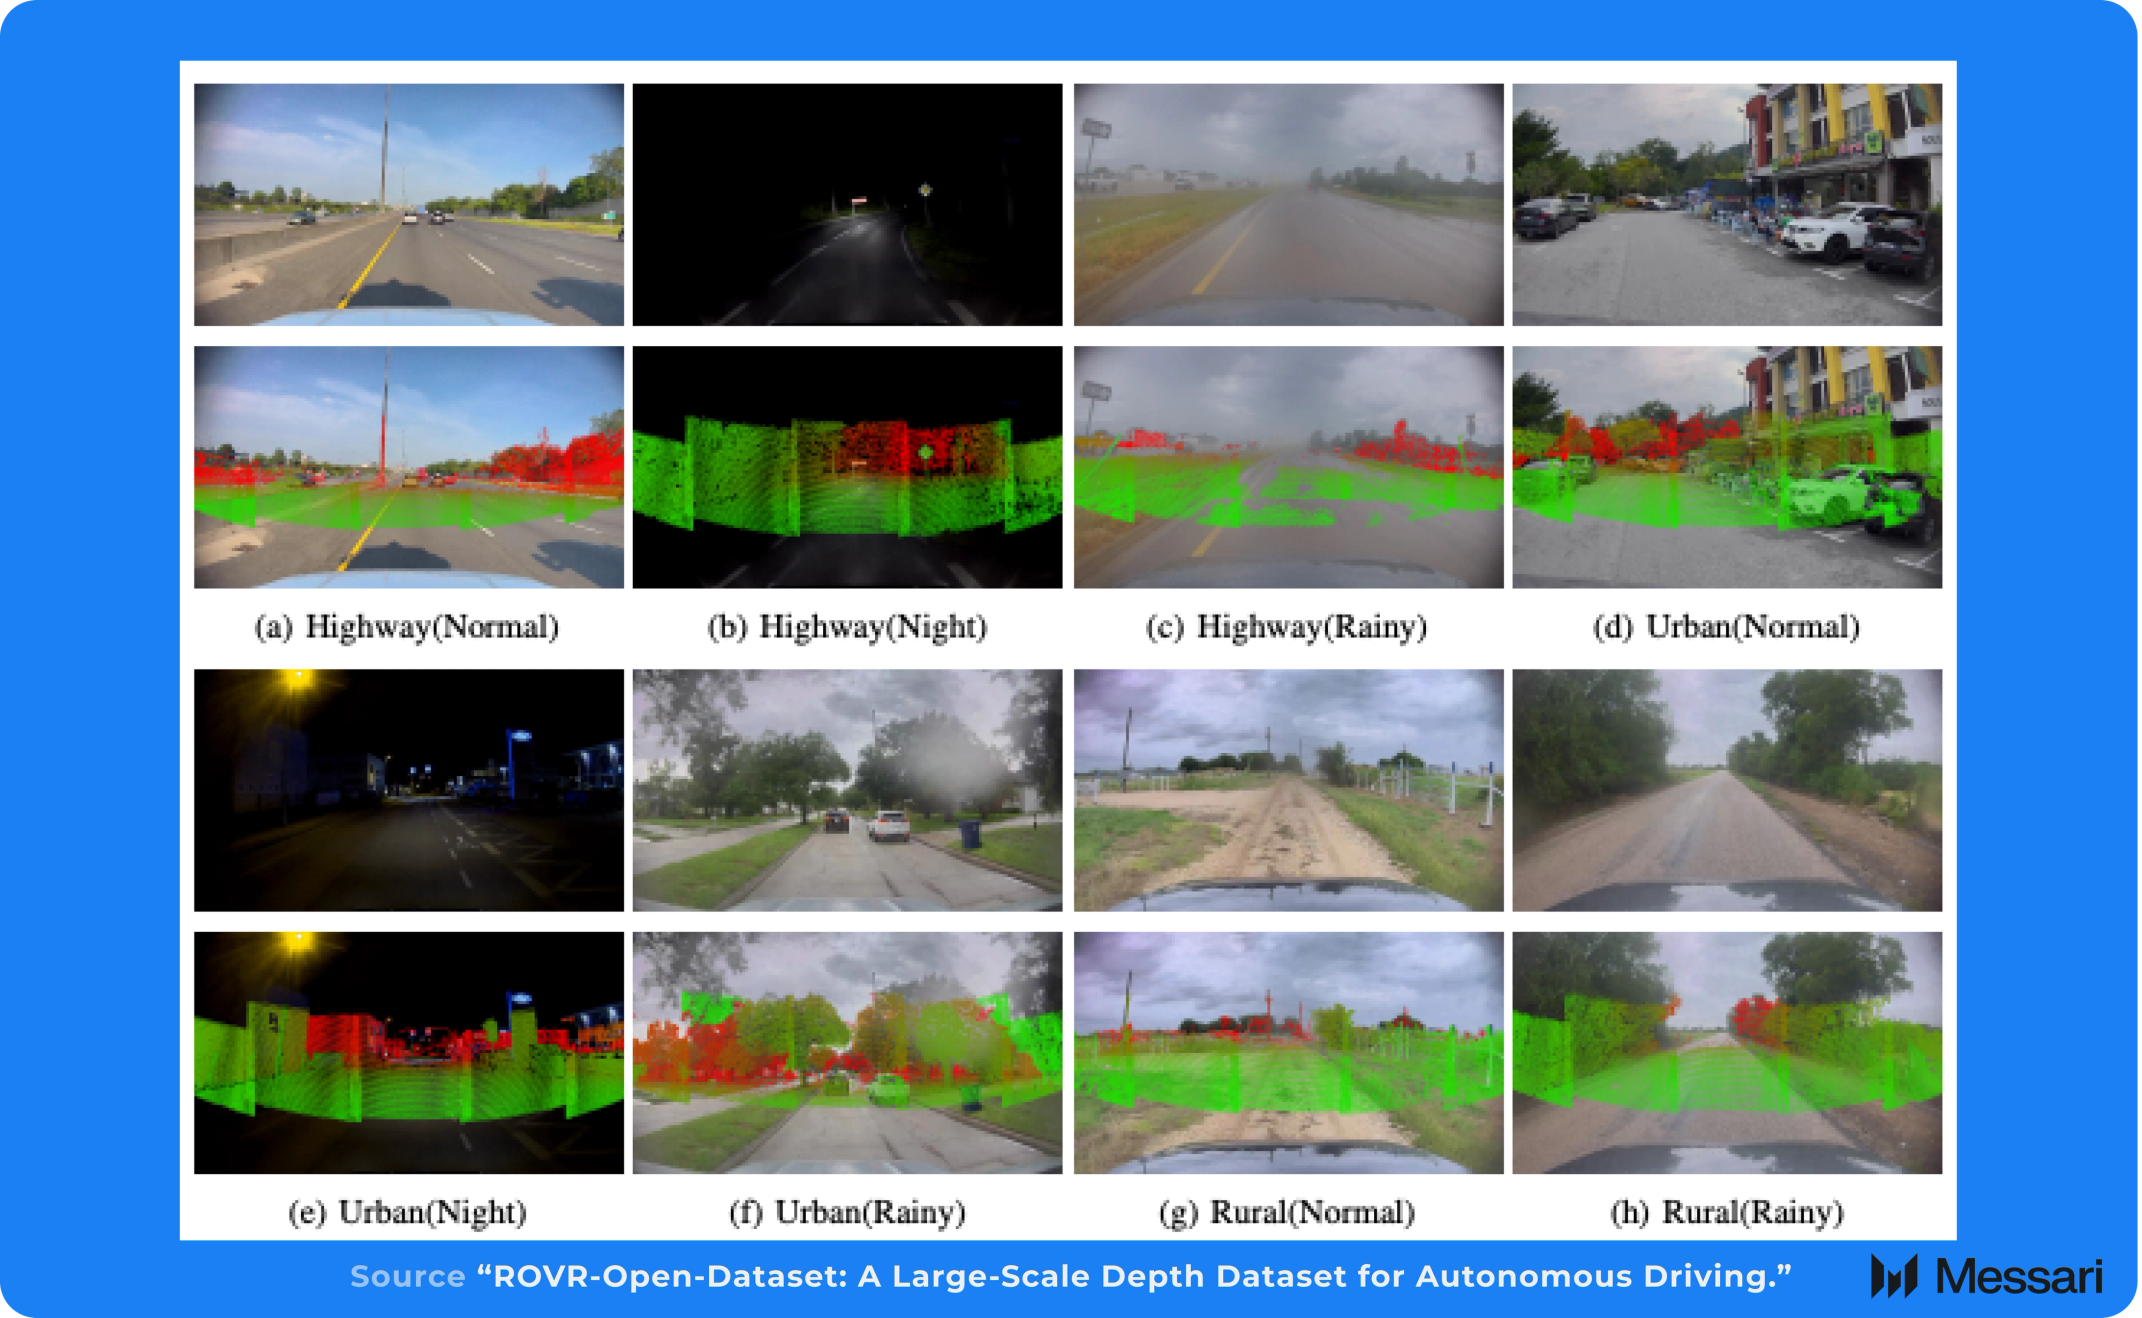
ROVR’s decentralized model naturally promotes global and environmental diversity. Its dataset spans more than 100 countries, with contributors mapping highways, urban centers, rural roads, and complex intersections across various climates and surface conditions. This organic expansion offers unique advantages in capturing rare edge cases, underrepresented geographies, and emerging road environments that may be missing from more centralized datasets.
NVIDIA’s dataset is geographically concentrated, with roughly half of its data originating from the U.S. and the remainder from 24 EU countries. This provides strong coverage of developed-world driving scenarios but less representation of the global South or rapidly urbanizing regions. Waymo’s dataset is the most regionally focused, centered on six U.S. metro areas, but it is also deeply sampled for environmental conditions (day, night, rain, dawn/dusk) and infrastructure types (urban, suburban, highways).
ROVR offers unmatched breadth, NVIDIA balances diversity with operational control, and Waymo delivers depth within targeted cities. This has significant implications for research on transfer learning, rare-event detection, and global model generalization.
Annotation & Label Quality
ROVR’s initial public dataset provides annotations for monocular depth estimation, with plans to expand into object detection and semantic segmentation in future releases. Its open approach supports decentralized annotation and validation, but the pipeline for human quality assurance and annotation consistency is still maturing, and the current dataset does not yet match the annotation density of its peers.
NVIDIA’s dataset currently includes ego motion (vehicle pose, velocity, acceleration) as machine-generated labels, with additional object and road element annotations planned. Annotations are generated online (automatic labeling) rather than through extensive human review, with efforts to expand labeling coverage and quality in response to community needs. Waymo’s Open Dataset, by contrast, is industry-leading in annotation scope and rigor. It includes over 12 million 3D labels (vehicles, pedestrians, cyclists, signage), 1.2 million 2D image labels, 3D and 2D semantic segmentation, keypoints, panoptic segmentation, and comprehensive multi-sensor object tracking, all created and reviewed by trained human labelers using proprietary annotation tools.
Accessibility & Licensing
ROVR’s Open Dataset is available under a dual-license model: non-commercial research use is permitted under Creative Commons BY-NC-SA 4.0, while commercial licensing (CC BY 4.0) is available for broader applications, subject to agreement and proper attribution. Access requires signing an agreement (with the responsible party and point of contact for institutions), but there are no institutional or geographic restrictions, and redistribution is possible with permission.
NVIDIA’s dataset, in contrast, is strictly gated. Access is only permitted for internal autonomous vehicle and ADAS development using NVIDIA technology, and the license prohibits surveillance, law enforcement, biometric analysis, or any derivative redistribution. Waymo’s dataset is the most accessible among the proprietary offerings, providing researchers with a non-exclusive, royalty-free, personal license to use and modify the data for non-commercial purposes, subject to the acceptance of terms and conditions through a Google account.
Cost Structure
ROVR incentivizes contributors through token rewards, lowering the cost of data acquisition for the network and enabling open access for developers and researchers once agreements are in place. For users, there is no direct cost for non-commercial research access; commercial licenses may incur fees, but the token-incentivized model is designed to keep barriers low and accelerate adoption.
NVIDIA and Waymo, while offering their datasets at no cost to approved research users, indirectly monetize through hardware sales, cloud infrastructure, and ecosystem partnerships. Direct access is free, but the broader ecosystem is closely tied to each company’s core commercial interests.
Update Frequency
ROVR’s dataset is continuously updated by a global contributor base, allowing for real-time or near-real-time expansion as new data is uploaded and validated. This organic update cycle supports rapid scaling and responsiveness to emerging research needs.
NVIDIA and Waymo follow more traditional, centralized update cycles. New data releases are periodic and curated, reflecting internal project milestones and strategic priorities. While this ensures quality and consistency, it may limit the pace at which novel scenarios or regions are incorporated into the dataset.
ROVR’s Strategic Positioning
ROVR’s Competitive Advantages
ROVR’s open data access, community-driven scaling, and global contributor model create a strong moat against closed, proprietary data collection approaches. By incentivizing participation and lowering barriers to contribute, ROVR is positioned to capture rare road scenarios, edge cases, and underrepresented geographies that are difficult or cost-prohibitive for centralized fleets to obtain. The project’s emphasis on APIs, SDKs, and integration tooling further enhances its flexibility, making it an attractive foundation for a broad range of spatial AI and robotics applications.
Potential Ecosystem Integrations
ROVR’s composable architecture and open data model position it as a foundational layer for spatial AI, enabling integration with AI research labs, robotics companies, mapping platforms, and even consumer automotive manufacturers. Its decentralized approach makes it naturally synergistic with emerging trends in Web3, decentralized AI, and participatory infrastructure development, offering a bridge between blockchain-based incentives and real-world data utility.
What’s Next for ROVR
Roadmap Considerations
ROVR’s near-term priorities include enhancing data quality tooling, automating pre-labeling and filtering, and improving marketplace interfaces to streamline contributor onboarding and data utilization. As the annotation pipeline matures and contributor incentives are refined, the network aims to close the gap with proprietary datasets in terms of labeling density and quality control.
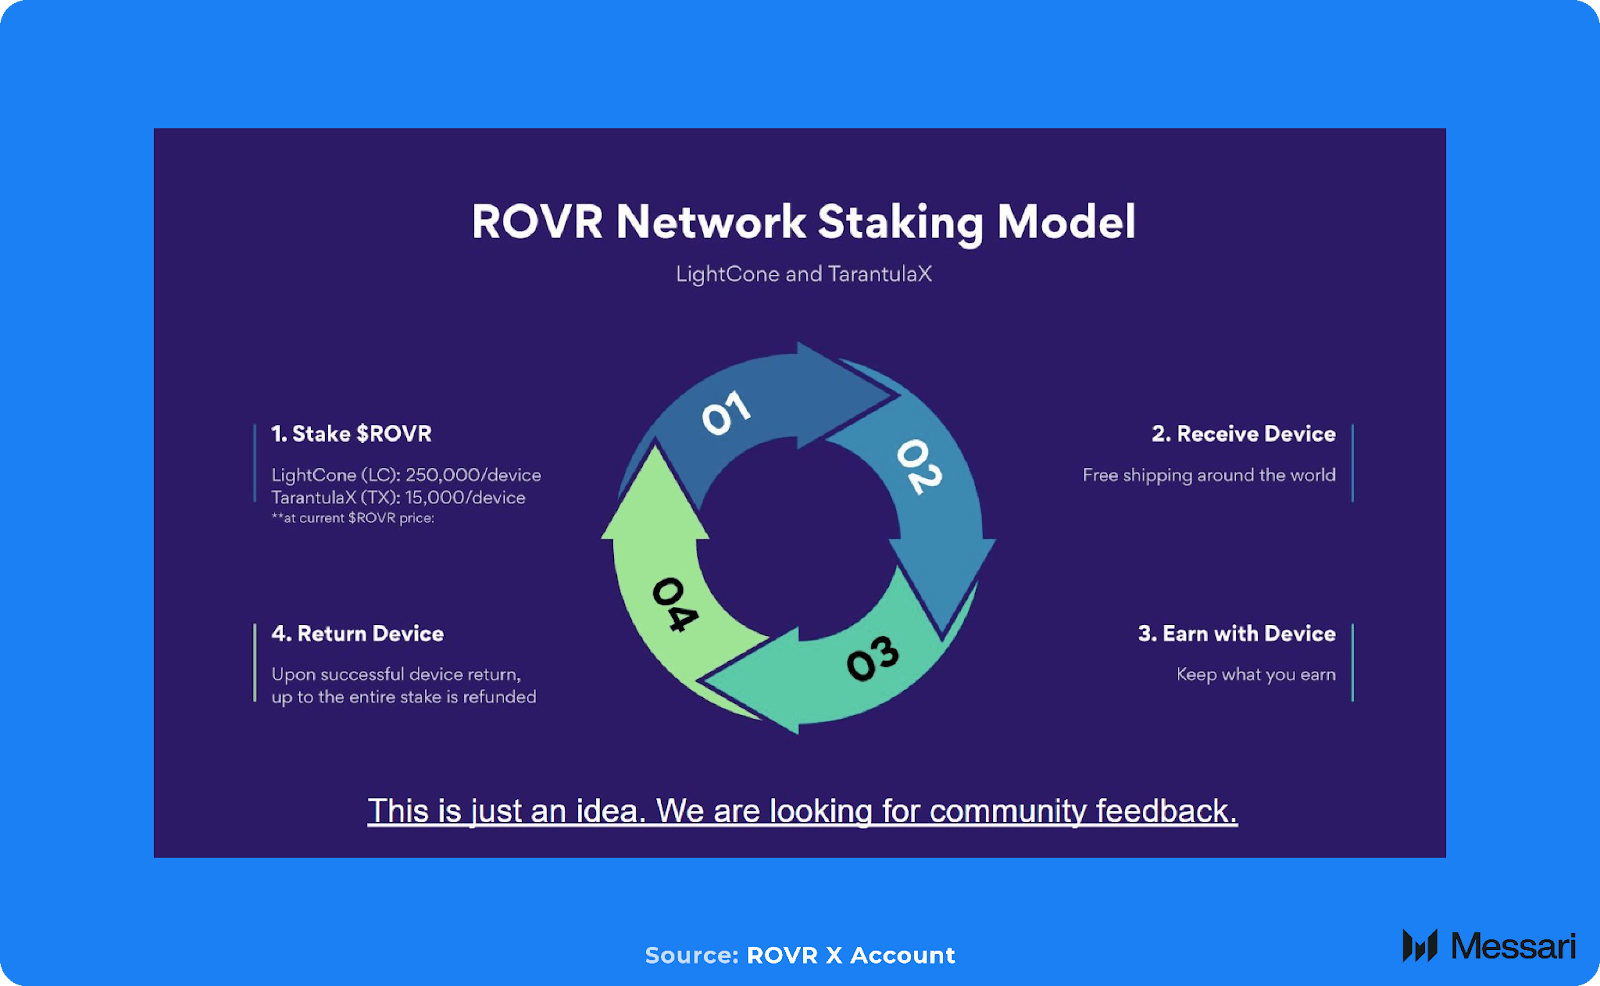
There is community interest in developing staking mechanisms to enhance contributor accountability, facilitate hardware rental, and enable slashing for low-quality or malicious uploads. Today, ROVR charges $2499 for the LightCone device and $199 for the TarantulaX device. The team has proposed that, with staking, users would stake the equivalent amount of ROVR tokens, and once the device has been successfully returned, they would receive their stake back. The potential for such functionality remains an open area for protocol innovation.
Closing Summary
The competitive landscape for autonomous vehicle and spatial AI datasets is rapidly evolving, shaped by a fundamental tension between the centralization of data quality and the decentralization of data access. ROVR Network’s model, built with open infrastructure, global participation, and tokenized incentives in mind, contrasts with the proprietary, vertically integrated approaches of NVIDIA and Waymo. Each model brings unique strengths: ROVR prioritizes breadth, adaptability, and participation; NVIDIA and Waymo deliver depth, consistency, and high annotation fidelity.
Ultimately, the future of AV and spatial AI research will likely be shaped by the interplay of these directions. Open, decentralized data networks like ROVR promise to democratize access, accelerate innovation, and surface edge cases that closed systems may never encounter, but they must overcome challenges in standardization, quality control, and contributor alignment.
This report was commissioned by ROVR Network. All content was produced independently by the author(s) and does not necessarily reflect the opinions of Messari, Inc. or the organization that requested the report. The commissioning organization may have input on the content of the report, but Messari maintains editorial control over the final report to retain data accuracy and objectivity. Author(s) may hold cryptocurrencies named in this report. This report is meant for informational purposes only. It is not meant to serve as investment advice. You should conduct your own research and consult an independent financial, tax, or legal advisor before making any investment decisions. Past performance of any asset is not indicative of future results. Please see our Terms of Service for more information.
No part of this report may be (a) copied, photocopied, duplicated in any form by any means or (b) redistributed without the prior written consent of Messari®.
Matthew is a Research Analyst in Protocol Research. He graduated from MIT with a Master's and Bachelor's in Comp Sci, Economics, and Data Science where he wrote his thesis on DeSoc. Matthew also has previous experience as an Analyst at Goldentree's crypto fund.
Matthew is a Research Analyst in Protocol Research. He graduated from MIT with a Master's and Bachelor's in Comp Sci, Economics, and Data Science where he wrote his thesis on DeSoc. Matthew also has previous experience as an Analyst at Goldentree's crypto fund.